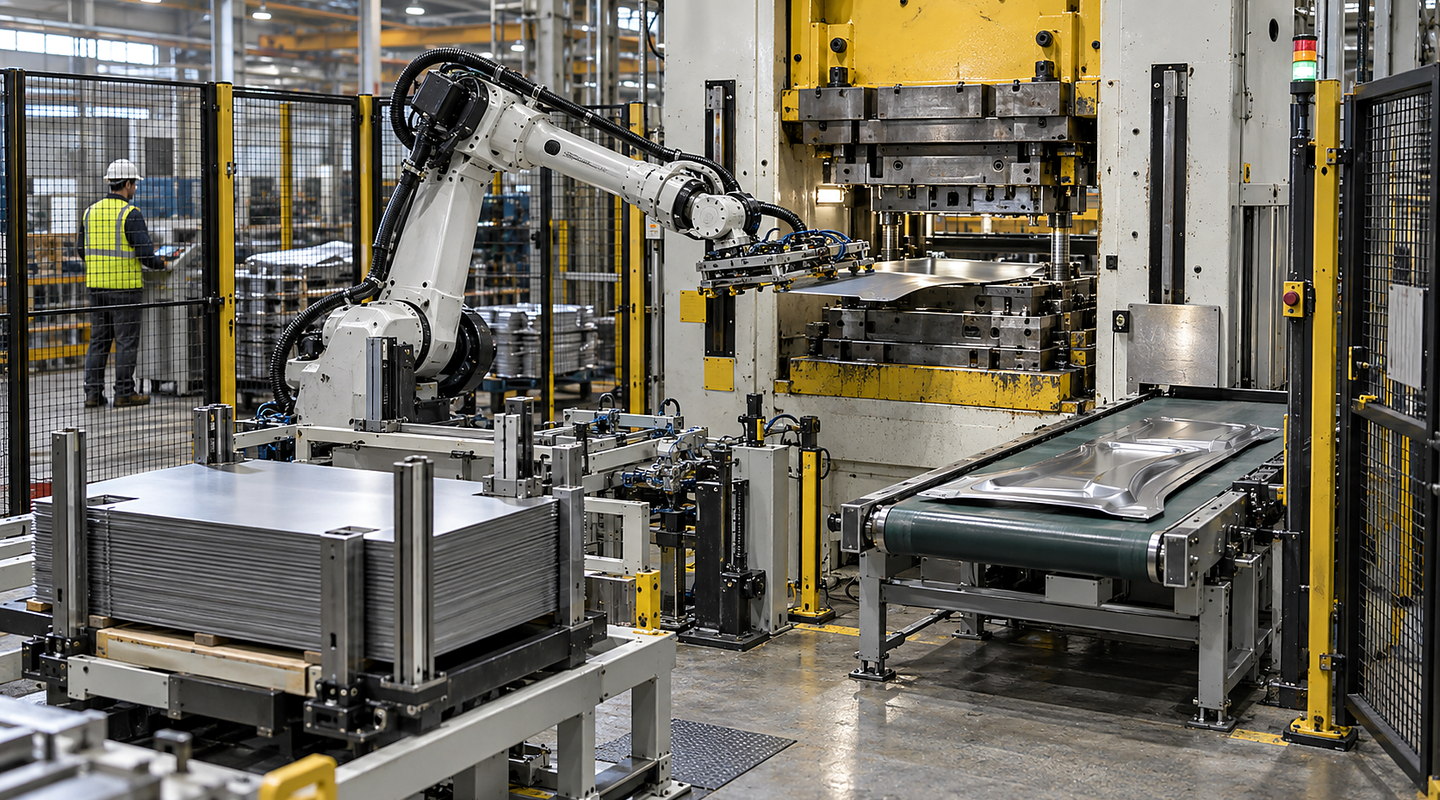
Sheet Metal Loading Robots: How the Process Works
Follow the operating sequence for sheet metal loading robots, from preparing the input and controlling the main task to handling exceptions and checking results.
Plan robotic sheet-metal loading from the arriving stack through separation, pickup, transfer, placement and release at the receiving machine. Agree how single-sheet pickup, acceptable surface condition and completed placement will be checked before treating a transfer as successful.
Use representative sheet sizes, thicknesses, weights, surface conditions and protective film. The run-off checklist connects these conditions to placement, double-pick, damage and recovery evidence.
Understand the complete route from input to accepted output — Sheet Metal Loading Robots
Plan sheet metal loading robots around your parts, process, cycle time, tooling, recovery and acceptance criteria. Discuss the highest-risk feasibility questions with Oxford Industrial Automation. Follow the material or part through each operating step and include recovery, cleaning and change in the real cycle.
Discuss your application

Four clear stages for sheet metal loading robots
At each stage, you can review how part, product and process variation for robotic sheet-metal machine loading and run-off criteria and production evidence affect the next commitment.
- 01
Observe the Current Process and Collect Representative Samples
Provide representative sheets and examples of their normal stacked delivery. Record dimensions, thickness, weight, surface condition and protective film, together with the required placement and current receiving-machine delays.
- 02
Prove Handling and Process Risks in a Focused Feasibility Trial
Use an agreed feasibility trial to examine separation, gripping, transfer and release with the proposed sheet range. Record double picks, incomplete transfers and surface marks separately from successful placements; do not extend a result from one sheet condition to every format.
- 03
Design and Build the Complete Guarded Cell
Review stack location, transfer space, receiving-machine access and the information exchanged before loading and after placement. Define responsibilities for machine readiness, sheet release and an interrupted transfer before the cell interface is agreed.
- 04
Run Agreed Scenarios and Support Production Ramp-Up
Review representative production, stack replenishment and format changes using the agreed acceptance criteria. Record placement and surface results, interruptions and recovery observations alongside the complete cycle, including receiving-machine delays.
Decisions and results stay connected
| Stage | What happens | What you can review |
|---|---|---|
| Observe the Current Process and Collect Representative Samples | Confirm the requirements for robotic sheet-metal machine loading, the operating range and the definition of a good result. | Your samples, current information and any points that still need confirming. |
| Prove Handling and Process Risks in a Focused Feasibility Trial | Compare workable methods using part, product and process variation for robotic sheet-metal machine loading and arrival pattern and presentation from your real production. | The trial method, observations and reason for the recommended route. |
| Design and Build the Complete Guarded Cell | Resolve required cycle and production pattern, tooling, sensing and process interfaces and the physical, control, safety and data connections. | The agreed layout, line connections and any changes from the proposal. |
| Run Agreed Scenarios and Support Production Ramp-Up | Check normal, difficult and fault conditions before your team takes over the system. | Results for operator access, recovery and changeover and run-off criteria and production evidence, plus actions and operating information. |
Keep connected responsibilities clear
Your final sheet metal loading robots scope must also account for operator access, recovery and changeover, run-off criteria and production evidence, current regulations and the conditions at your site.
- Cycle time depends on the complete process rather than robot speed alone.
- Part presentation, tolerances and recovery cases must be included in feasibility work.
- Collaborative operation or automatic handling cannot be assumed safe without an application assessment.